
Gears for Surgical Robotics
Precision Motion, Reliable Transmission, and Compact Design
Surgical robotics supports surgeons during selected complex procedures by translating control inputs into carefully coordinated instrument movements. Precision gears are an important part of many robotic drive systems, helping manage speed, torque, positioning, and motion. Their design must balance accuracy, compact size, durability, and reliable operation within the requirements of each surgical platform.
From compact planetary gearboxes to miniature bevel and worm gear mechanisms, different gear designs support different functions within surgical robots. This guide explains common gear types, material considerations, design challenges, and emerging technologies, showing how thoughtful gear engineering contributes to controlled motion and dependable system performance.
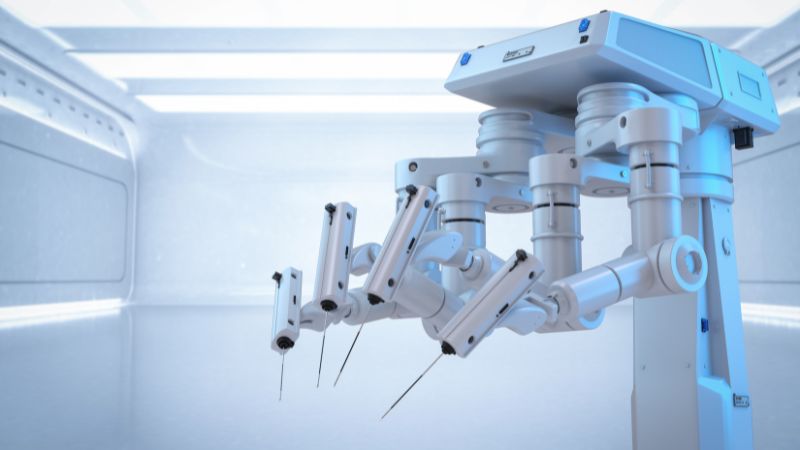
Evolution of Surgical Robotics
Surgical robotics has developed from early research platforms into systems designed for a growing range of clinical applications. Improvements in actuation, sensing, control software, and precision transmission—including gear design and manufacturing—have helped make robotic instruments more capable and compact.
The PUMA 560 became an early milestone in surgical robotics when it was adapted for use in procedures such as neurosurgical positioning. Early platforms relied on the available robotic actuators and mechanical transmissions, with capabilities shaped by the control and manufacturing technology of the time.
The late 1990s and following years brought wider clinical attention to robotic-assisted minimally invasive surgery, including the introduction of the da Vinci Surgical System. Improvements in instrument articulation, motion scaling, and control helped surgeons perform selected procedures through small incisions; specific transmission designs vary by platform.
Purpose-built robotic platforms expanded into different specialties. Their mechanical transmissions were increasingly tailored to the required motion range, load, packaging, and instrument design, while improvements in manufacturing and inspection supported tighter control of component quality.
Research and development placed greater emphasis on lightweight materials, wear behavior, compact mechanisms, and improved sensing. In systems that provide force or tactile feedback, the transmission and sensors must work together to represent instrument interaction as accurately as the platform design allows.
Current systems combine precision mechanics with advanced actuators, sensors, imaging, and software. Gear specifications and manufacturing methods depend on the component size, material, production volume, and required performance; no single tolerance or process applies to every surgical robot.
How Precision Gears Support Surgical Robotics
The potential benefits of robotic-assisted surgery depend on the procedure, platform, clinical team, and patient. Within the mechanical system, precision gears can support controlled motion, compact instrument design, and repeatable transmission. They are one part of a broader system that includes software, sensors, actuators, and surgeon control.
 Enhanced Surgical Precision
Well-designed gear trains help translate motor commands into controlled instrument movement. Overall positioning accuracy depends on the complete system—including encoders, control algorithms, mechanical compliance, calibration, and instrument design—not gears alone.
 Minimally Invasive Approach
Compact transmission mechanisms can help support articulated instruments used in minimally invasive procedures. Incision size, recovery, complication risk, and other clinical outcomes depend on the procedure and many clinical factors; they should not be attributed to gear design alone.
 Expanded Surgical Capabilities
Appropriately designed transmissions can support wrist-like articulation, motion scaling, and controlled movement in confined spaces. The achievable range of motion is determined by the full instrument and robotic architecture, including joints, cables, motors, and software.
 Improved Ergonomics for Surgeons
Console-based robotic systems can offer an ergonomic operating position and map surgeon inputs to instrument movements. Gear ratios and friction affect the feel and responsiveness of controls, while overall ergonomics depend on the console, workflow, and individual user.
 Telesurgery Possibilities
Remote operation places additional demands on motion control, communication reliability, latency management, and system safety. Low-backlash transmissions can help preserve motion fidelity, but they are only one of many requirements for any telesurgery application.
 Improved Procedural Outcomes
Reliable mechanical transmission can contribute to consistent instrument movement over repeated operating cycles. Clinical outcomes, however, vary by procedure, patient, surgeon experience, and care setting; claims about complication rates or long-term results should be supported by procedure-specific clinical evidence.
Essential Gear Types in Surgical Robotics
Surgical robot gear systems must fit strict packaging, motion, torque, noise, wear, and reliability requirements. The most suitable configuration depends on the joint or instrument being driven, the available space, the expected load, and the required positioning performance.
Planetary Gear Systems
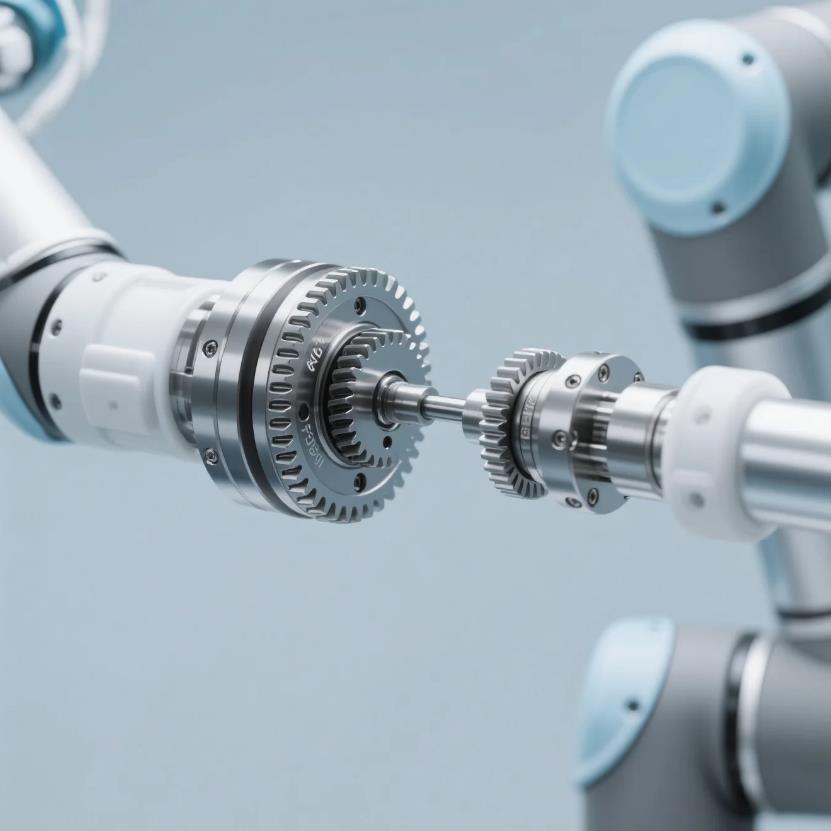
Planetary gear systems arrange several planet gears around a central sun gear, providing a compact way to achieve useful reduction ratios and transmit torque. Depending on the design, they can offer:
- High torque density in a compact package
- Excellent power transmission efficiency (>95%)
- Precise motion control with minimal backlash
- Even load distribution across multiple gear teeth
- Primary application in robotic arm joints and main drive systems
Material selection should reflect load, wear, cleanliness, lubrication, and the component’s exposure to cleaning or sterilization. Titanium alloys and engineering polymers may suit particular designs, but neither is a universal choice for every gear train.
Helical Gears
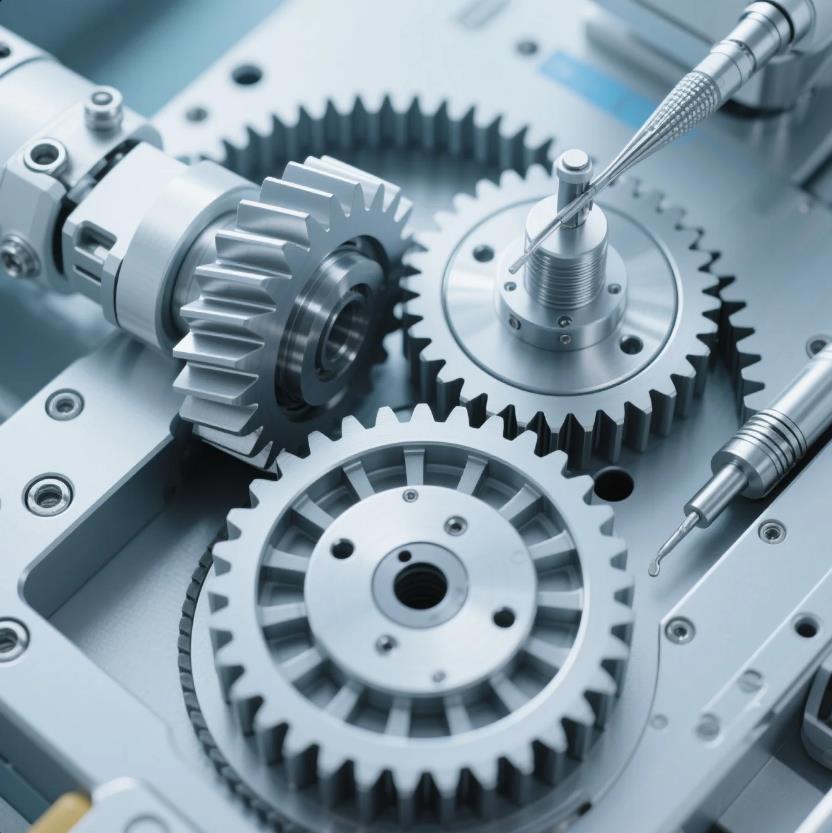
Helical gears have angled teeth that engage progressively rather than all at once. When correctly designed and supported, they can offer:
- Exceptionally smooth and quiet operation
- Gradual tooth engagement reducing vibration
- Higher load-carrying capacity than straight spur gears
- Excellent for continuous operation during lengthy procedures
- Often used in instrument rotation mechanisms and precision control systems
Designers must account for axial thrust, bearing support, lubrication, and alignment when using helical gears. Their suitability depends on the transmission layout and operating requirements.
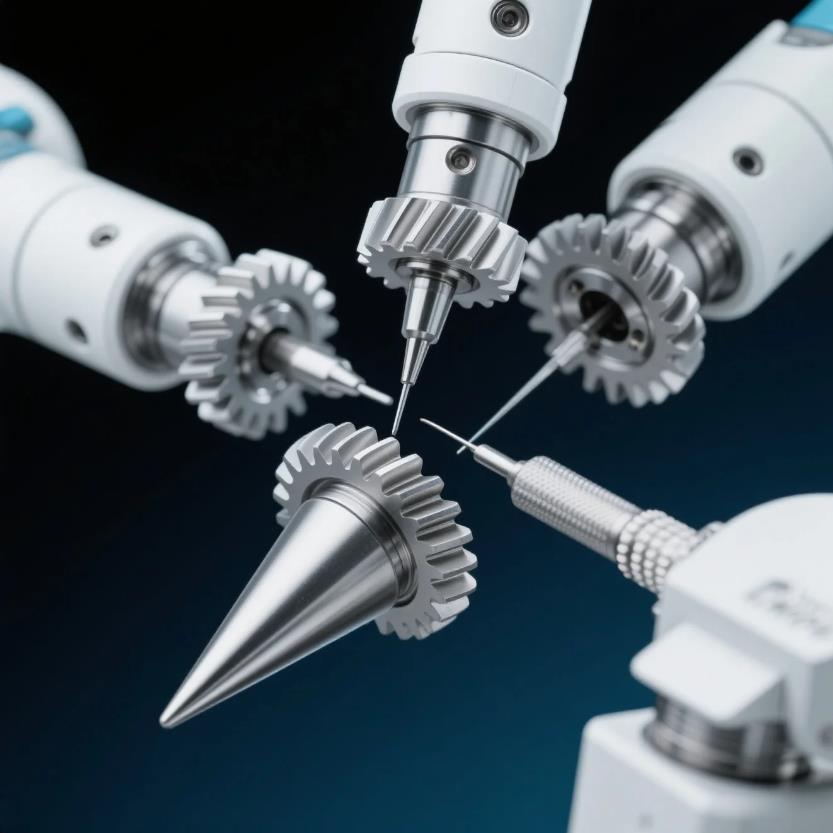
Bevel Gears
Bevel gears transmit motion between intersecting shafts and can help redirect drive power within compact instrument mechanisms. Common configurations include straight and spiral bevel gears, each with its own trade-offs:
- Enable 90-degree (or other angle) power transmission
- Critical for wrist-like movements in robotic end effectors
- Available in straight, spiral, and hypoid configurations for different applications
- Facilitate complex multi-axial movements in confined spaces
- Enable the miniaturization of articulating instrument tips
Spiral bevel gears may provide smoother engagement than straight bevel gears in suitable designs, but selection also depends on space, load, manufacturing capability, and alignment requirements.
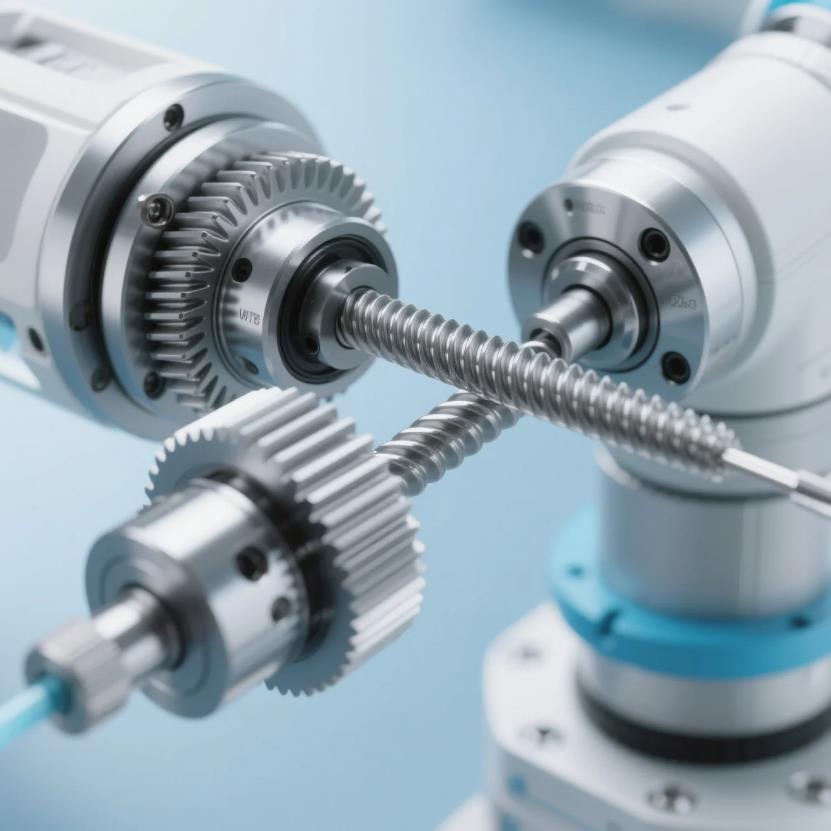
Worm Gear Systems
Worm gear sets use a worm and worm wheel to provide right-angle transmission and potentially high reduction in a compact arrangement. Their characteristics can be useful in selected positioning or adjustment mechanisms:
- Inherent self-locking capability for maintaining position
- Extremely high reduction ratios (20:1 to 300:1) in a single stage
- Smooth, precise movement ideal for fine adjustments
- Right-angle power transmission in compact spaces
- Commonly used in instrument positioning systems and locking mechanisms
Worm gear efficiency varies with geometry, materials, surface finish, and lubrication. Any coating or lubricant must be validated for the component’s operating environment and applicable cleanliness or sterilization requirements.
Specialized Gear Applications in Surgical Systems
In addition to conventional gears, surgical robots may use specialized reducers and compact transmission mechanisms. Their value depends on the motion, stiffness, backlash, size, and load requirements of the specific joint or instrument.
Advanced Materials in Surgical Robot Gears
Gear materials should be selected for the intended load, wear life, corrosion resistance, dimensional stability, manufacturability, and exposure conditions. The table below gives general examples; final choices require application-specific engineering review.
| Material | Key Properties | Applications |
|---|---|---|
|
Medical-Grade Stainless Steels (17-4PH, 316L) |
Corrosion resistance, sterilization compatible, good wear resistance | General-purpose gears in non-patient-contact applications |
|
Titanium Alloys (Ti-6Al-4V ELI) |
Exceptional strength-to-weight ratio, biocompatibility, non-magnetic | MRI-compatible systems, weight-critical applications |
|
PEEK (Polyether Ether Ketone) |
Self-lubricating, lightweight, excellent chemical resistance | Low-load applications, gear systems requiring autoclave sterilization |
|
Nickel-Titanium Alloys (Nitinol) |
Superelasticity, shape memory, biocompatibility | Specialized compliant mechanisms, adaptive gear systems |
|
Ceramic Components (Zirconia, Silicon Nitride) |
Extreme hardness, wear resistance, non-magnetic | High-precision bearing surfaces, wear-critical components |
Surface treatments may improve wear or corrosion behavior in some applications. Their suitability should be confirmed through testing for the selected substrate, lubricant, cleaning process, and service conditions:
- DLC (Diamond-Like Carbon) Coatings: Provide exceptional wear resistance and low friction, extending gear life in continuous-use surgical systems
- Passivation Treatments: Enhance corrosion resistance for components exposed to biological fluids or sterilization chemicals
- Antibacterial Surface Treatments: Emerging technologies incorporating silver or copper ions to reduce infection risks
Recent Technological Advances
Progress in surgical robotics combines mechanical engineering with improvements in sensing, control, manufacturing, and system integration. Several areas are influencing how precision gear systems are designed:
AI Integration
Software and data-driven control can support motion planning and system monitoring. Where sensors measure position or load, reliable mechanical transmission helps the control system interpret and execute commands; the role of AI varies by platform and intended use.
Haptic Feedback
Some robotic platforms provide force-related cues or haptic feedback, while others do not. When feedback is part of the design, friction, backlash, compliance, sensor placement, and signal processing all influence how faithfully forces can be represented to the operator.
_1746586793_WNo_512d512.png)
Miniaturization
Miniaturized mechanisms can help designers fit more functionality into limited instrument space. Achievable dimensions and tolerances depend on the selected process, material, geometry, and production controls; specific figures should be verified against the component specification.
Engineering Challenges in Surgical Robot Gear Design
Designing gears for surgical robotics involves trade-offs among precision, durability, size, manufacturability, and cost. Common considerations include:
Sterilization Compatibility
Where a component is exposed to sterilization, its material, lubricant, seals, and dimensional stability must be compatible with the specified process and number of cycles. Not every gear is directly exposed to steam; requirements depend on whether the component is reusable, enclosed, or part of a disposable instrument.
Backlash Minimization
Backlash can affect positioning and response, especially when motion reverses. Designers may use precision tooth geometry, preloaded arrangements, or alternative reducers to manage backlash while accounting for friction, wear, temperature, and manufacturing variation.
Miniaturization Constraints
As gears become smaller, tooth geometry, surface finish, inspection access, assembly, and dimensional variation become harder to control. Micro-machining, specialized molding, and other precision processes may be suitable depending on the design and material.
Biocompatibility Requirements
Biocompatibility requirements apply according to the nature and duration of patient contact and the relevant regulatory framework. Designers must evaluate the complete finished component—including materials, coatings, residues, and wear debris—where applicable.
Balancing Precision and Cost
Tighter tolerances and specialized materials can increase manufacturing and inspection costs. A practical design balances the precision actually required with production repeatability, service life, assembly needs, and total system cost.
Reliability Demands
Reliability requirements should be defined for the intended service life, duty cycle, maintenance plan, and operating environment. Validation may include dimensional inspection, wear and endurance testing, lubrication checks, and testing of the assembled transmission.
